标题: OpenVINS: A Research Platform for Visual-Inertial Estimation
作者:Patrick Geneva, Kevin Eckenhoff, Woosik Lee, Yulin Yang, and Guoquan Huang
来源: 2020 IEEE International Conference on Robotics and Automation (ICRA)
编译:姚潘涛
审核:柴毅,王靖淇
这是泡泡一分钟推送的第 624 篇文章,欢迎个人转发朋友圈;其他机构或自媒体如需转载,后台留言申请授权
摘要
在本文中,我们为学术界和行业从业人员提供了一个称为OpenVINS的开放平台,用于视觉惯性估计研究。开源代码库为研究人员和工程师快速开始视觉惯性系统新功能开发提供了基础。该代码库对通常需要的视觉惯性估计功能提供了开箱即用的支持,其中包括:(i)集成滑动窗口卡尔曼滤波器,(ii)在线摄像机固有和外部校准,(iii)摄像机到惯性传感器的时间偏移校准,(iv)具有不同表示形式和一致的First-Estimates Jacobian(FEJ)处理的SLAM地标,(v)用于状态管理的模块化类型系统,(vi)可扩展的视觉惯性系统模拟器以及(vii)用于算法评估的广泛工具箱。此外,我们还关注于详细的文档和理论推导,以支持快速的开发和研究,而当前的开源算法却大大缺乏这些理论和推导。最后,我们针对最新的开源算法对建议的OpenVINS进行了全面验证,显示了其竞争性的估计性能。
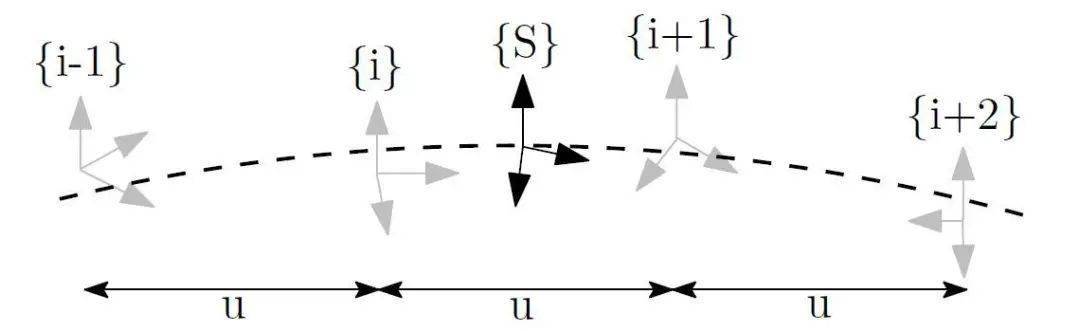
图1 说明B样条插值到以四个控制姿态为边界的姿态T。
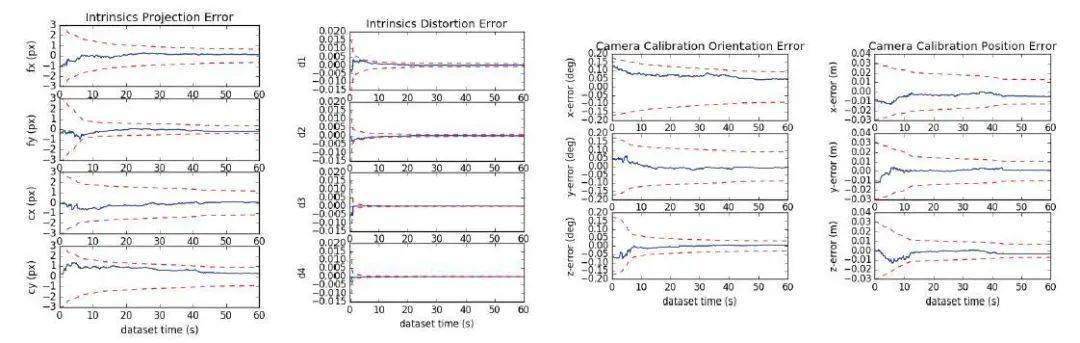
图2 相机的固有投影和变形以及外部取向和位置参数误差(蓝色实线)和3σ边界(红色虚线)用于代表行程。请注意,我们仅绘制数据集的前60秒。
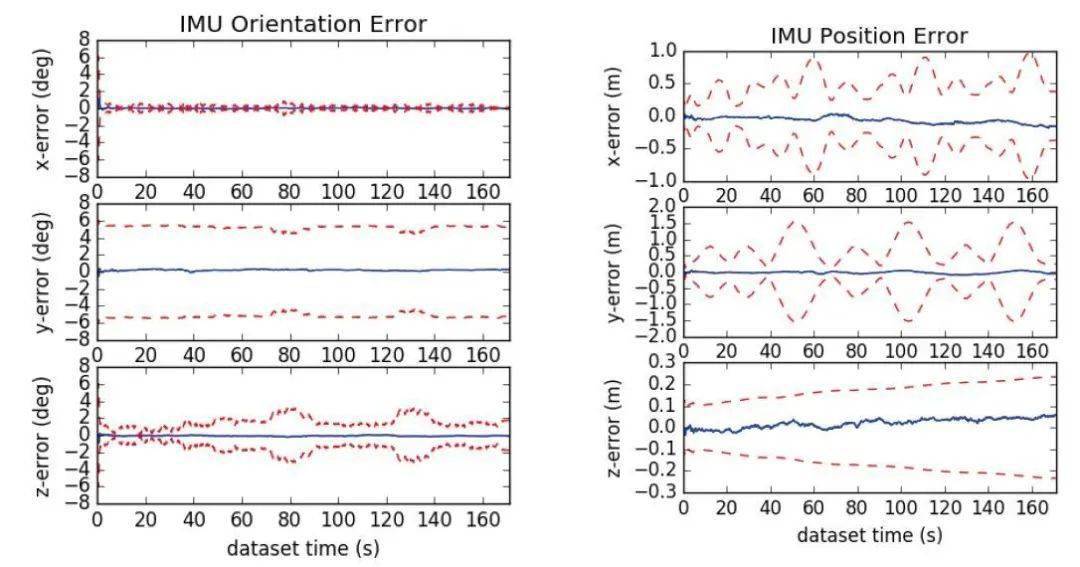
图3 IMU姿态误差(蓝色实线)和3σ界限(红色虚线)代表了使用SLAM地标和在线校准的拟议方法的代表性运行。
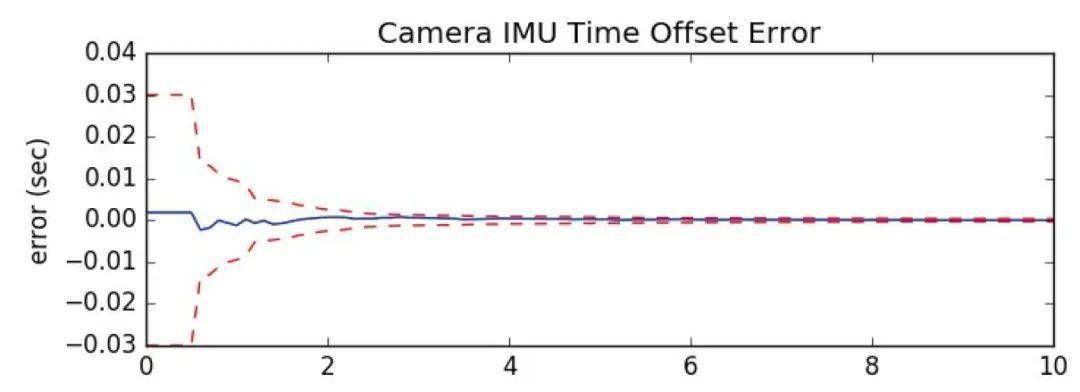
图4 代表运行的摄像机到IMU的时间偏移误差(蓝色实线)和3σ边界(红色虚线)。
表1 在有或没有在线校准的情况下,通过真实校准或不良校准,平均进行20次以上的TE和NEES测试。
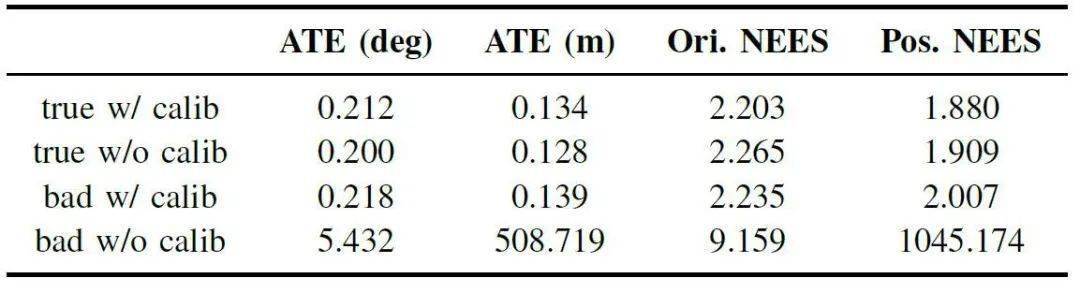
表2 每种算法的十次运行平均绝对轨迹误差(ATE)以度/米为单位。请注意,由于某些算法无法在其上运行,因此排除了V2 03数据集。绿色代表最好,而蓝色代表第二。
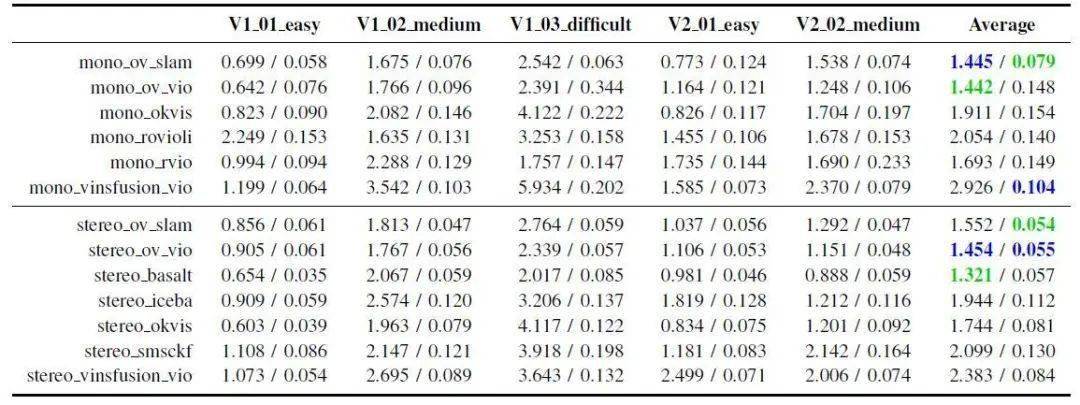
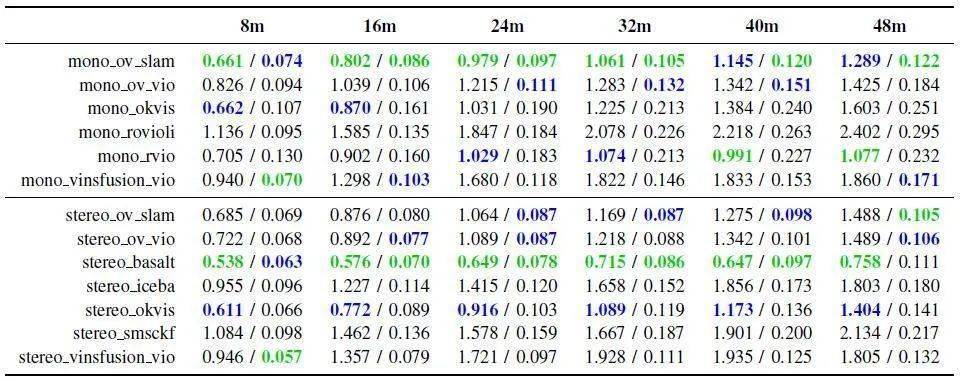
表3 在所有数据集上,每种算法变化的不同段长度的相对姿态误差(RPE),以度/米为单位。请注意,由于某些算法无法在其上运行,因此排除了V2_03数据集。
Abstract
In this paper, we present an open platform, termed OpenVINS, for visual-inertial estimation research for both the academic community and practitioners from industry. The open sourced codebase provides a foundation for researchers and engineers to quickly start developing new capabilities for their visual-inertial systems. This codebase has out of the box support for commonly desired visual-inertial estimation features, which include: (i) on-manifold sliding window Kalman filter, (ii) online camera intrinsic and extrinsic calibration, (iii) camera to inertial sensor time offset calibration, (iv) SLAM landmarks with different representations and consistent First-Estimates Jacobian (FEJ) treatments, (v) modular type system for state management, (vi) extendable visual-inertial system simulator, and (vii) extensive toolbox for algorithm evaluation. Moreover, we have also focused on detailed documentation and theoretical derivations to support rapid development and research, which are greatly lacked in the current open sourced algorithms. Finally, we perform comprehensive validation of the proposed OpenVINS against state-of-the-art open sourced algorithms, showing its competing estimation performance.
百度网盘提取码:tujc
泡泡机器人SLAM的原创内容均由泡泡机器人的成员花费大量心血制作而成,希望大家珍惜我们的劳动成果,转载请务必注明出自【泡泡机器人SLAM】微信公众号,否则侵权必究!同时,我们也欢迎各位转载到自己的朋友圈,让更多的人能进入到SLAM这个领域中,让我们共同为推进中国的SLAM事业而努力!
商业合作及转载请联系liufuqiang_robot@hotmail.com返回搜狐,查看更多